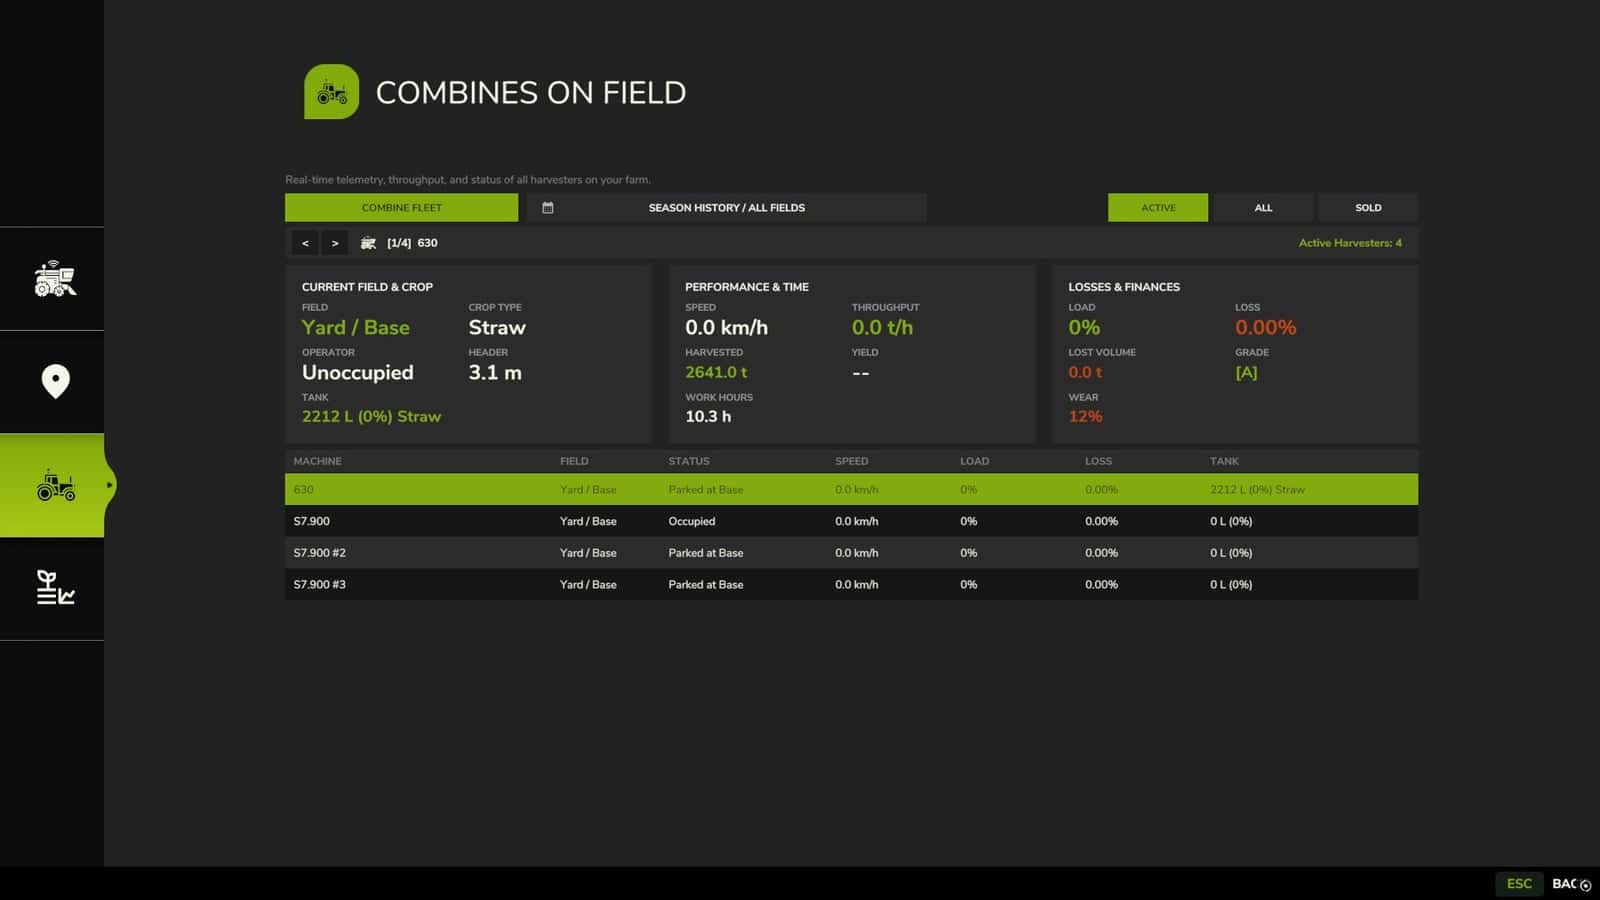
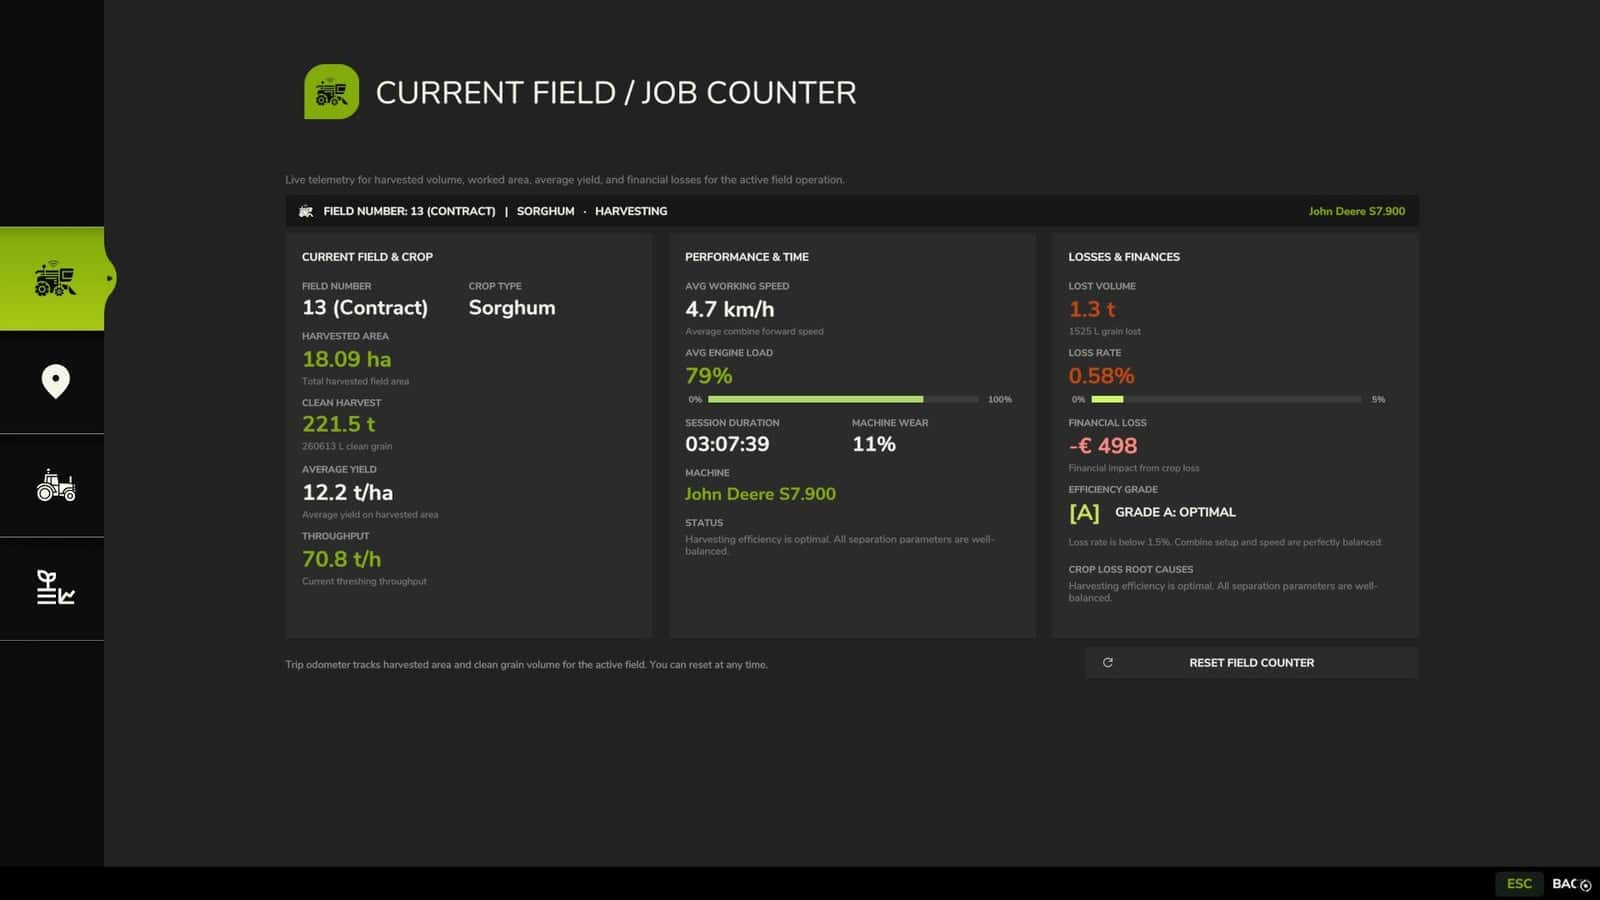
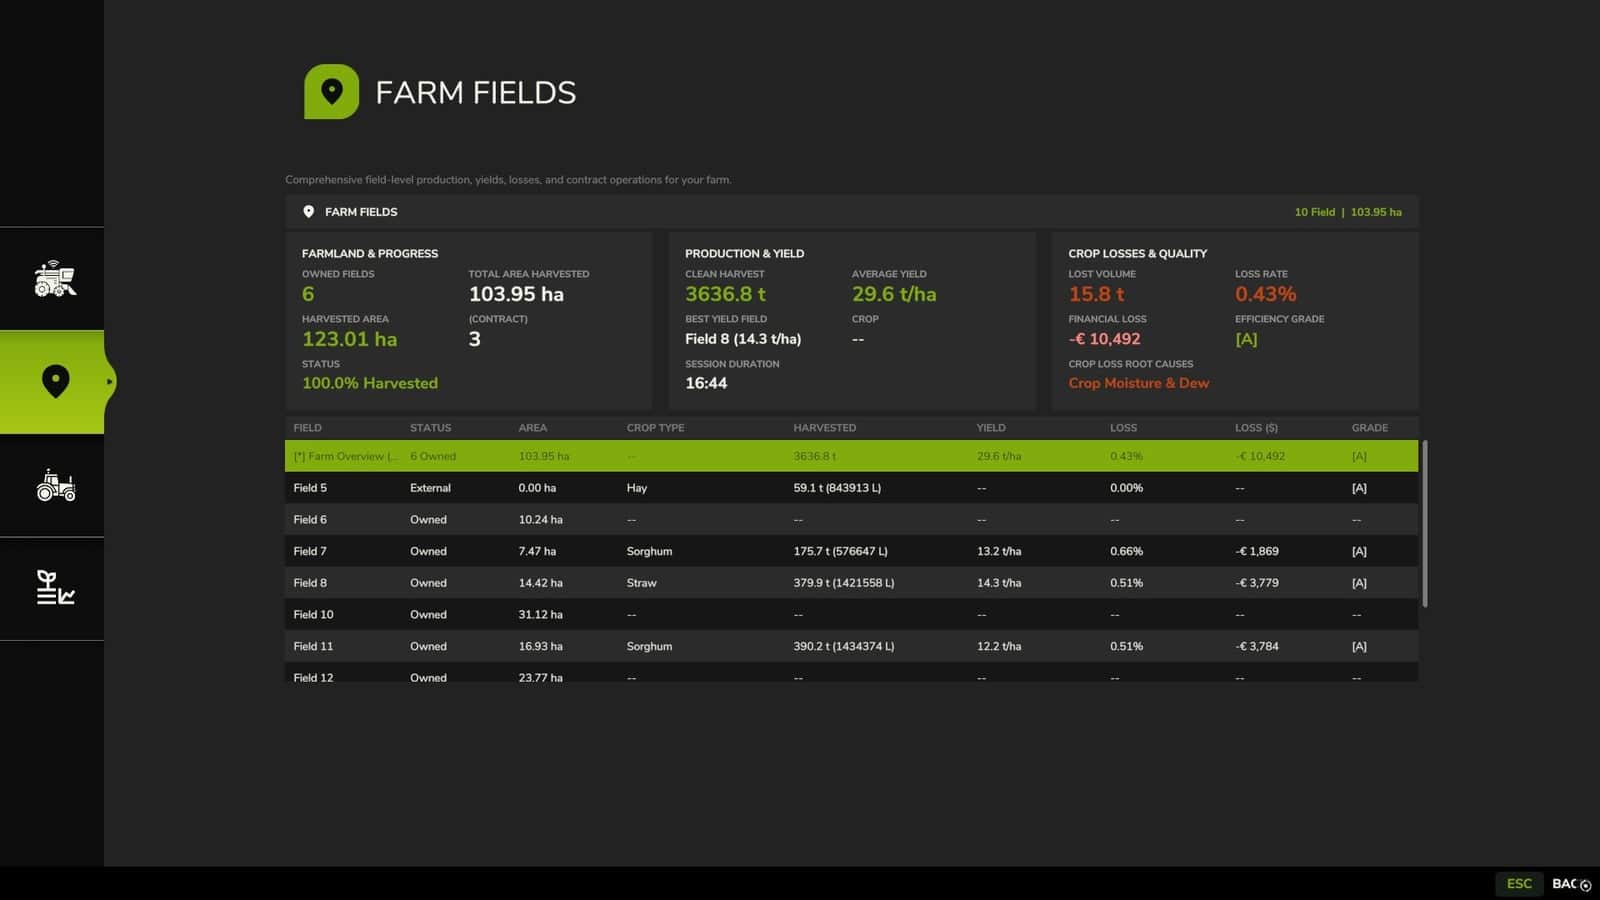
Realistic Harvesting for FS25 adds dynamic harvesting mechanics based on crop density, cutting width, moisture, machine horsepower, and mechanical calibration.
Features
- Physics-based engine load and speed: Ground speed dynamically adapts based on harvested crop mass (t/h), header width, and vehicle horsepower. Overloading the engine or using incorrect settings results in real grain loss.
- All machine types supported: Fully calibrated physics for Grain Combines, Forage Harvesters (chaff/silage), Root & Vegetable Harvesters (potatoes, beets, carrots, parsnips, spinach, peas), Cotton, and Sugarcane.
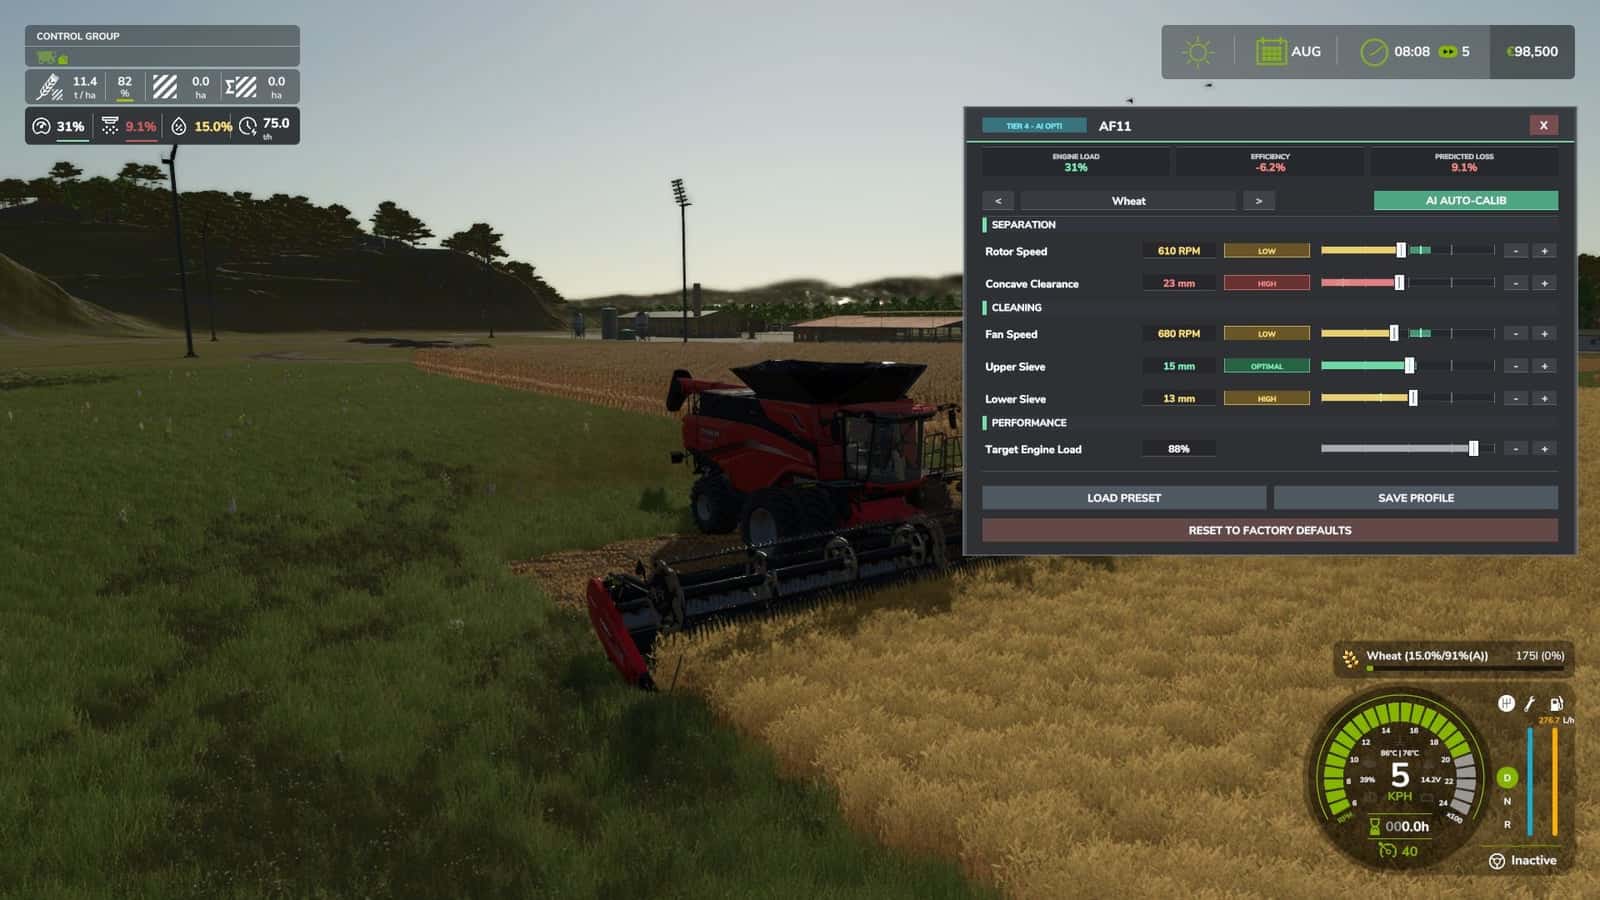
- Interactive Combine Calibration (
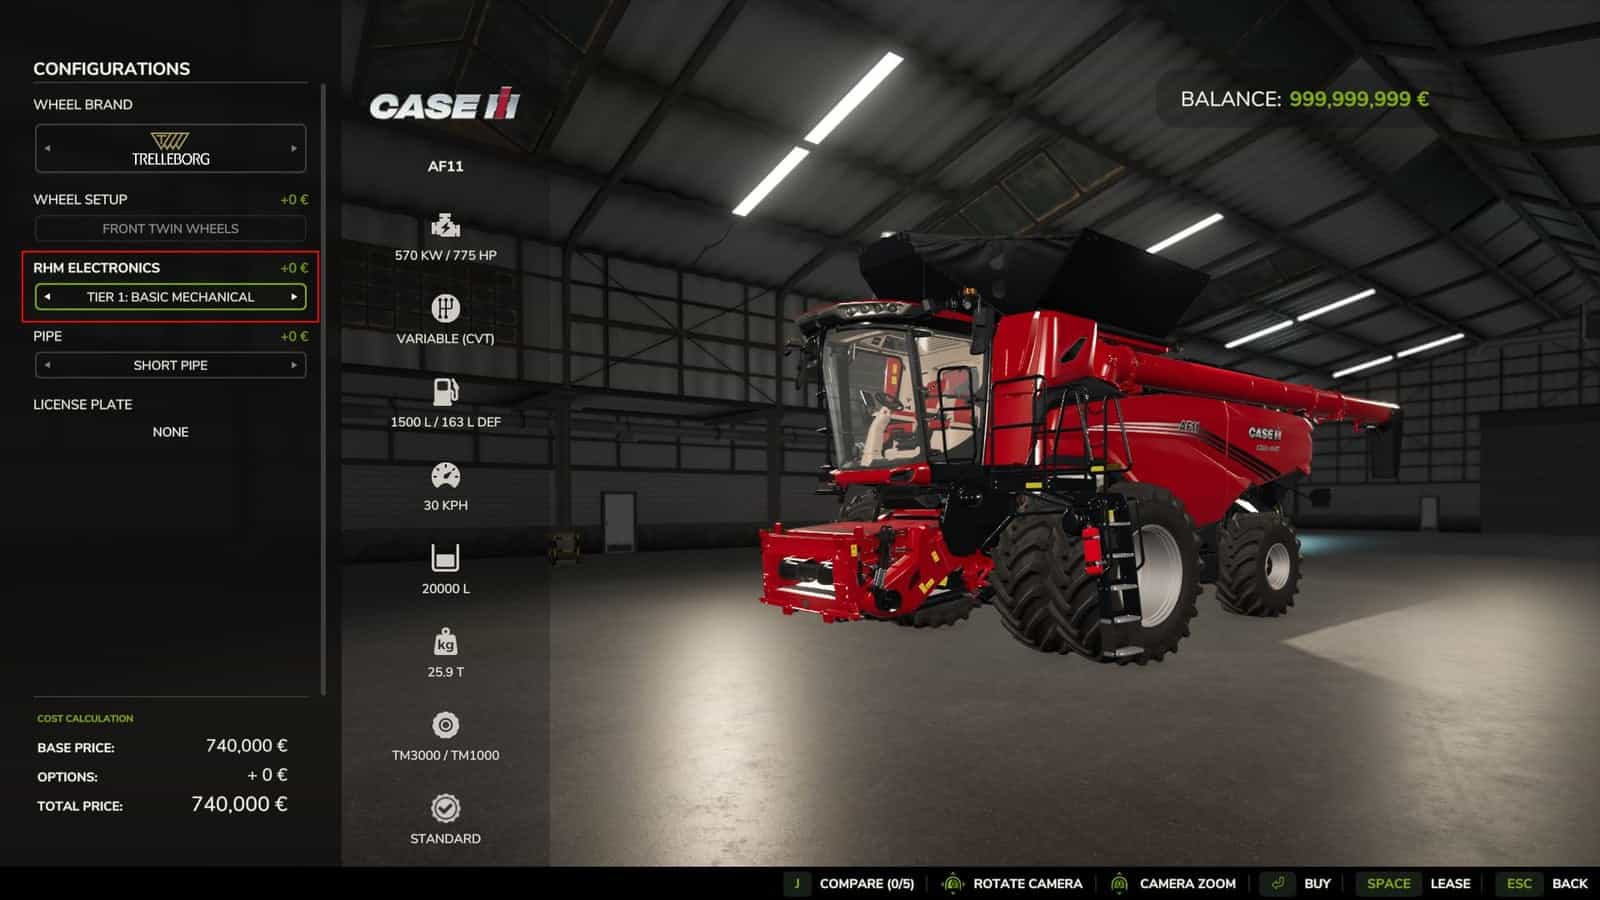
RShift + K): Calibrate Rotor/Drum RPM, Concave Clearance, Fan Speed, and Sieves for each crop. Correct settings ensure maximum yield and minimum loss. - Workshop Upgrade Packages (Tiers 1-4): Upgrade your combine at the shop.
- Level 1 (Standard): Fully manual operation.
- Level 2 (Sensor Kit): Displays calibration guidance hints (low / optimal / high).
- Level 3 (Yield Monitor): Real-time yield (t/ha, bu/ac), area rate (ha/h), and moisture telemetry.
- Level 4 (Opti-Harvest AI): Automatic settings calibration and automated speed management.
- AI & Courseplay compatibility: AI helpers and Courseplay workers automatically utilize your saved profiles or optimal calibrations.
- Draggable HUD: A movable on-screen display showing live Engine Load, Productivity (t/h, ha/h), Crop Loss %, and Moisture.
- Global Crop Profiles: Save your tuning once, and profiles automatically load across your combines and savegames.
- 3 Difficulty Modes (ESC Settings): Arcade (relaxed), Normal (balanced), or Realistic (strict physical limits and penalties).
Changelog
- V1.6.4.1
- FIXED: Harvester calibration hotkeys (Shift+K), HUD toggle (Shift+H), and Harvest Diary (Shift+J) response when attached implements (headers/cutters) are selected in the vehicle tool chain via native interaction and activation flags.
- FIXED: Modular harvesters and system carriers (NEXAT / NEXCO) threshing system classification. The NEXCO combine module is now accurately recognized and displayed as Axial Rotor instead of falling back to straw walkers.
- FIXED: Live harvest telemetry, speed regulation, and header lowering detection on modular multi-vehicle and gantry harvesting platforms where cutters are mounted to the motorized carrier rather than the threshing module directly.
- IMPROVED: Expanded automatic combine classification for modded and serial grain harvesters, adding support for Torum, Gleaner, Tribine, New Holland CH Crossover, Case IH AF series, and classic conventional harvesters.
- IMPROVED: Deep 3D model node inspection (i3dMappings) for custom modded combines that lack standard animation tags, ensuring machines with physical rotor or axial components are reliably identified.
- FIXED: An issue where switching between combines, for example from Tier 4 to Tier 1, left the calibration terminal (Shift+K) bound to the previous machine, falsely displaying Tier 4 settings.
- FIXED: Shift+K calibration terminal failing to open on modular carrier harvesters whenever an attached header/cutter implement was selected.
- REMOVED: Grain Threshing Subtypes. Removed the division of grain combines into
walker,rotor, andhybridsubtypes, unifying all conventional grain harvesters under a single"grain"standard. - REASON FOR REMOVAL: Fragile name-matching lists and complex XML animation node lookups frequently failed on modded combines, causing false classifications, XML callstack warnings, and inconsistent power balance. Unifying grain combines into a single robust model guarantees 100% stability across all vanilla and modded harvesters without affecting forage, root crop, or specialty harvesters.
- V1.6.4.0
- New Features, Threshing Mechanism Classification System: Implemented an automated classification engine in
rhm_Combine.luathat classifies harvesters into 6 mechanical categories based on vehicle XML data, wheel count, and chassis dimensions: STRAW WALKER(conventional straw walker combines).AXIAL ROTOR(single and dual longitudinal rotor systems).HYBRID APS(accelerator pre-separation cylinder with twin separation rotors).FORAGE CHOPPER(precision-chop drum and accelerator systems).ROOT HARVESTER(lifting shares, sieving webs, and cleaning rollers).SPECIALTY(cotton, sugarcane, grape, and olive harvesters).- Added a real-time Threshing System Indicator badge to the Shift+K calibration terminal header.
- Added public API endpoint
RHM_Api.getThreshingType(vehicle). - Added localized naming across all 27 language files (
translations/l10n_*.xml). - 3-Way HUD Work Rate & Productivity Monitoring: Implemented interactive click-cycling in Yield Monitor HUD Cell 7 (expanded layout) and Cell 4 (compact layout).
- Cycles between: Processed Area (ha / ac) <-> Instantaneous Work Rate (ha/h / ac/h) <-> Session Average Work Rate (ha/h / ac/h).
- Added session average work rate telemetry to the Trip Statistics frame.
- Added public API method
RHM_Api.getAverageHectaresPerHour(vehicle). - Improvements & Optimizations, Native GIANTS Engine 10 Cutter Specialization: Migrated cutter logic into an official GIANTS Engine 10 vehicle specialization (
rhm_Cutter), completely replacing runtime monkey-patching ofCutter.onLoad. - Registered
<specialization name="rhm_Cutter" />inmodDesc.xmland dynamically injected it across all cutter vehicle types. - Differentiated Power Balance and Moisture Physics: Differentiated base driveline drag according to threshing architecture (8.0% for straw walkers, 9.5% for hybrid APS, 11.0% for axial rotors, 10.0% for root harvesters, 9.0% for forage harvesters).
- Refactored moisture processing drag in
RHM_LoadCalculator.lua: straw walkers receive an exponential resistance penalty in damp, clumped straw mats, whereas rotary systems maintain steady crop flow with lower specific moisture resistance. - Differentiated moisture separator loss rates across mechanism types.
- Multiplayer Telemetry Synchronization: Added high-frequency network stream replication (
onWriteUpdateStream/onReadUpdateStream) for burned fuel, average speed, average engine load, all 5 loss breakdown reasons (speed, settings, moisture, wear, slope), and concave clearance. - GUI & Telemetry Responsiveness: Reduced analytics and trip refresh loops to a 250ms cadence with explicit open/close reset handlers, resolving frozen telemetry values.
- Upgraded throughput monitoring to simultaneously display instantaneous peak and session average throughput (t/h).
- Bug Fixes, Modular Carrier & Gantry Combine Support: Resolved an issue where harvesters mounted as detachable modules on motorized gantry carriers displayed zeroed HUD telemetry and failed to record odometer trip data.
- Implemented zero-allocation implement tree traversal (
rhm_Combine.getAllAttachedCutters) to discover cutters attached directly to the carrier chassis. - Updated cutter working width calculations, weed biomass sampling, cruise speed regulation, wear loss calculations, and field tracking across modular equipment configurations.
- Crab-Steering & Diagonal Motion Handling: Fixed false-positive reverse detection on vehicles equipped with crab-steering, all-wheel steering, or wide-span travel modes where local chassis Z-vector displacement is non-positive despite forward directional velocity and active crop intake.
- Ensured active crop flow acts as an immediate bypass for motion direction validation.
- Cutter Lowering & Working State Detection: Fixed an issue where rigid, non-hydraulic implement attachers failed the recursive
getIsImplementChainLoweredcheck. - Switched cutter lowered validation to direct implement state (
cutter:getIsLowered(true)) with direct joint check fallback. - Added a carrier ground speed fallback in
RHM_DraggableHUD.luawhen an attached combine module reports < 0.2 km/h due to decoupled root nodes. - Engine Crash Guard & Dedicated Server Permissions: Added strict type validation (
type(flag) == "number") prior to invokingvehicle:raiseDirtyFlags(flag), preventing native enginebit32.borcrashes. - Fixed Dedicated Server permission validation in
RHM_Settings.luaby evaluatingg_currentMission:getHasAdminRights()alongsideg_currentMission.isServerAdmin.
- New Features, Threshing Mechanism Classification System: Implemented an automated classification engine in
- V1.6.3.2
- Headland Speed Governing: Fixed an issue where harvesters remained speed-locked at harvesting crawl speeds (5 km/h) during headland turns. Lifting the header now immediately releases the motor to full maneuvering speed (15-20 km/h).
- Implement Chain & Hydraulic Verification: Prioritized authentic feeder house hydraulics (getJointMoveDown, getIsImplementChainLowered) over unfolded header states (Foldable:getIsLowered), preventing wide and draper headers from falsely reporting a lowered cutting state when lifted.
- Dedicated Server Live Telemetry Sync: Replaced unsupported bitwise operations with native GIANTS Engine 10 methods, fully restoring real-time network stream replication for engine load, throughput (t/h), yield, and recommended speed on multiplayer clients.
- Automated Helper Synchronization: Added synchronized header start/stop for helpers when separate header launch is active, and resolved live driver handover telemetry resets.